WidowX Heavy
Attention
Specifications on this page are preliminary and subject to change.
Overview
See Arms to compare the WidowX arms.
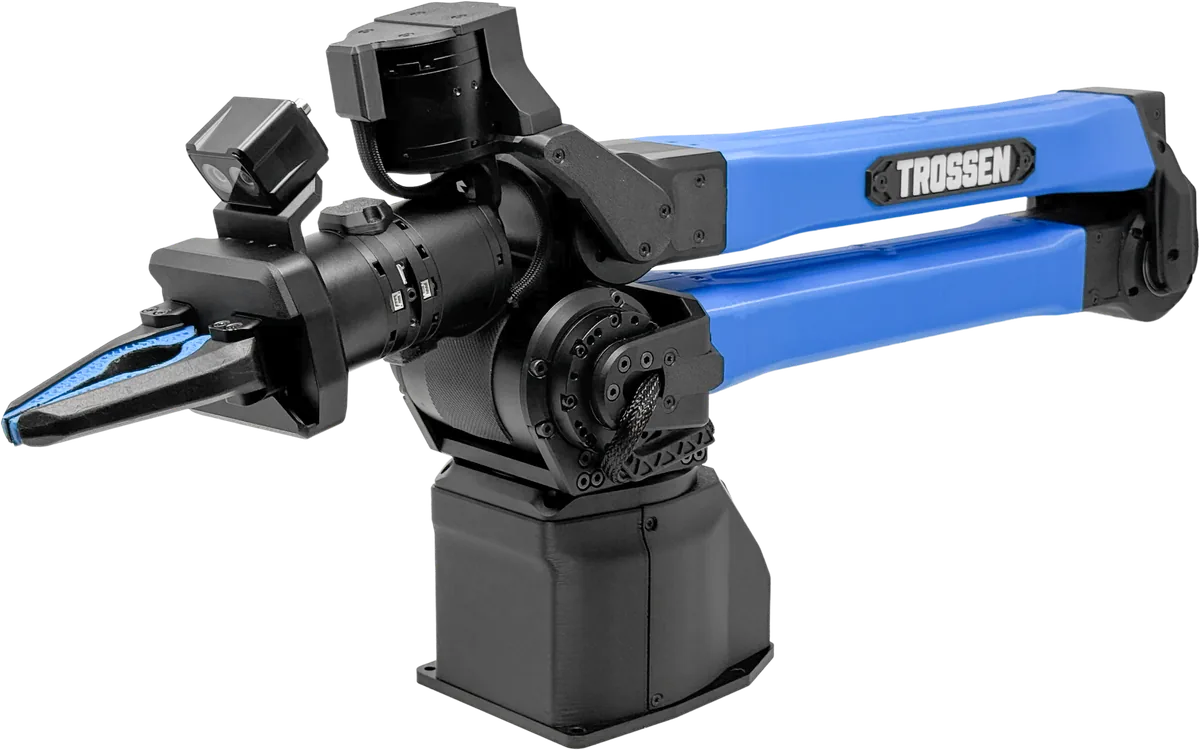
|
|
||||||||||||||||||
Joint Limits
Joint |
Min Position [rad (deg)] |
Max Position [rad (deg)] |
Velocity [rad/s (deg/s)] |
Effort [N*m] |
|---|---|---|---|---|
Joint 0 |
-2.8798 (-165) |
2.8798 (165) |
6.2832 (360) |
97 |
Joint 1 |
0 (0) |
3.8397 (220) |
6.2832 (360) |
194 |
Joint 2 |
0 (0) |
3.7525 (215) |
6.2832 (360) |
97 |
Joint 3 |
-1.5708 (-90) |
1.5708 (90) |
6.2832 (360) |
27 |
Joint 4 |
-1.5708 (-90) |
1.5708 (90) |
9.4248 (540) |
7 |
Joint 5 |
-2.0071 (-115) |
2.0071 (115) |
9.4248 (540) |
7 |
Note
These effort limits are nominal values. The actual limits are computed with the following formula:
where \(\text{effort_nominal}\) is the nominal effort limit of a joint, \(\text{effort_correction}\) is the effort correction factor of this joint, and \(\text{effort}_\max\) is the actual effort limit of this joint.
The effort corrections can be retrieved with trossen_arm::TrossenArmDriver::get_effort_corrections().
Controller Base
The controller base has three M12 connectors with different functions.
Coding |
Carries |
|---|---|
X Code |
Network |
A Code |
GPIO |
L Code |
Power |
The base also has the arm’s power switch, a status LED, and a small screen that can display and manage the arm’s state and configuration.